Prediction

Predict, don’t react.

Measurement-driven failover has a floor: probe interval × misses + smoothing. Fast platforms fall through it. The prediction layer feeds what the radios and the geometry already know — signal trends, positions, velocities, terrain — into the same per-link risk, and moves traffic before the failure. Opt-in, and advisory by principle.

Shipped · opt-in (prediction_source)Advises, never overrides
The lag

Probe interval + missed count + smoothing

At defaults: 250 ms probes and five misses, each counted once two intervals pass unanswered — ≈ 1.5–1.75 s to a hard verdict, with EWMA smoothing damping the early signal. That’s excellent for a substation and marginal for an airframe opening range at 20 m/s — it travels 30–35 m between “fine” and “gone”.
The insight

The future is already in the data

A fading RSSI trend, a diverging position track, a ridge sliding into the path — each predicts the failure seconds early. Atlas already carries all three signals: adapters feed radio telemetry, LSAs carry position and velocity, and the node reads the elevation tiles loaded on it.

The principle

Prediction is advisory

It biases scheduling and routing costs; it never declares a link dead and never falsifies a measurement. Probes remain the sole authority on death — prediction just makes sure there’s nothing left riding the link when they finally say so. Dashboards always show the measured truth.

Shipped · opt-in

EWMA level + slope, projected ahead

Adapter-reported RSSI is smoothed and its slope projected 2 s forward with a 6 dB margin. Projected below the floor (−88 dBm default), the scheduler sees inflated loss — capped at 75%, so the link is never fully abandoned by prediction alone — and traffic migrates before probes miss. Rising trends are never penalised; a link recovering is left alone.

Position & velocity

The geometry is public. Use it.

prediction_source = "position": nodes share GNSS position and velocity inside the routing flood. Both endpoints project each other along their tracks; links about to stretch out of range get a rising loss penalty locally and an SPF cost penalty (capped ×4) mesh-wide — so both packet scheduling and multi-hop routes bend before the geometry breaks.

Short-reach Wi-Fi + long-reach RFD900 on a departing airframeSimulation
WIFIactive link
—handoff lead time
0packets lost in gaps
Turn prediction off and the same pass produces the textbook failure: the short link carries until it silently dies, five probes must miss, and everything in that gap is gone. With it on, the handoff happens seconds early and the drop counter stays at zero.

Per-link range envelopes Shipped · opt-in

One global range model is wrong the moment the bond mixes radios. [[link]] max_range_m (with an optional warn radius, default 60% of max) scores each radio against its own reach: a 300 m Wi-Fi leg and a multi-kilometre telemetry-radio leg to the same airframe get different risk from the same distance — so the scheduler walks traffic onto the longer-legged link as range opens, before the short-range radio drops a single probe.

Position adverts that keep up with the airframe Shipped

Range prediction and the terrain weights in routing read advertised positions, so every node weighs an edge the same way and the routes stay loop-free. That makes the advert the clock: a node that re-advertised only on a link change or its 30 s refresh left every route that depends on its position up to 30 s behind it. A moving node now re-advertises when it moves, and a rate limit keeps a fast mover from flooding a slow radio.

TRIGGERS RATE LIMIT ON THE WIRE Moved 25 mfrom the last advert: one at once Movingat least every 10 s · still: nothing Terrain changeda path changed state, the node moved Minimum interval1 s by default, node-wide,however fast the node moves Ordinary linkat most one position advert per minimum interval Narrow beareronly at its own pacing interval, with the newest fix MEASURED a 220 m move reached the other nodes in 136–210 ms · behind a ridge, the route moved in about 0.5 s instead of about 23 s
THE TRIGGERSMoved 25 m: an advert at once. Moving: at least every 10 s. Standing still: nothing extra.
THE LIMITAt most one position advert a second by default; a narrow bearer keeps its own pacing.
MEASUREDA 220 m move seen by the others in 136–210 ms; a ridge reroute in about 0.5 s instead of about 23 s.
Triggers

Distance, period and terrain

Moving position_advert_distance_m (25 m) from the position in the last advert sends one at once. A node with a fix that has moved at all re-advertises at least every position_advert_interval_secs (10 s). When a neighbour path changes terrain state — clear, marginal, shadowed, unknown — and the node has moved since its last advert, its position goes out too. A parked or static node sends nothing more than before. The fix is checked four times a second, and the distance and the period apply live, without a restart.

Rate limit

Inside the bearer pacing, not beside it

A position advert is an ordinary routing flood, so it obeys the pacing every link already has. A link declared narrow with its own route_advert_interval_secs carries it only when that interval is due, coalesced with the newest fix; every other link carries position adverts at most once per position_advert_min_interval_secs, 1 s by default, node-wide, however fast the node moves. Both holds are counted in the snapshot’s position_adverts block, beside the adverts each trigger sent.

Defaults

Calm on the ground, quick in the air

25 m is about a second of fixed-wing flight, under two for a multirotor, and less than one 30 m elevation cell, so a smaller step would not change a terrain profile. A walking dismount advertises every 10 s. A survey aircraft that routes on a tighter picture sets the distance to 10 m, while its long-range radio, paced at 16 s, still carries one advert per 16 s.

Measured

From half a minute to half a second

A 220 m move reached the ground station and the relay in 136–210 ms. Moving 60 m every 200 ms, a drone sent about one advert a second on its ordinary link and one per pacing interval on its narrow one, and its last fix reached the ground station 0.7 s after it stopped. Behind a ridge, both ends moved their route through the relay about 0.5 s after the move, where before they waited about 23 s for the next refresh. Measured

Terrain awareness Shipped

The case relative geometry can’t see.

Range is not reachability. A formation can fly together, every distance unchanged, while a ridge slides into the path between two of its members; a drone can descend behind a hill three kilometres from its ground station without opening range at all. Signal and range prediction give that link a perfect score until it dies. The node loads elevation tiles, checks every path it knows against the ground, and moves traffic before the radio confirms the fade. Off by default; [terrain] enabled = true turns it on.

The blind spot

The ridge is the one thing in the scene that never moves, which is why nothing that watches motion sees it coming. Below, a drone descends behind a ridge at constant range. Its terrain risk to the ground station rises from 0 through 0.44 to 1: clear; then marginal, as the ridge enters the first Fresnel zone while the line of sight still clears it; then shadowed, 49 m below the line with 19.2 dB of diffraction loss. Within one pass the direct link’s score is set by terrain while the link still carries. On the drone’s next advert the ground station, the drone and a hilltop relay all route through the relay, and when the direct link then fails, the traffic loses nothing, because it has already left.

SIDE VIEW · ONE PATH, THREE MOMENTS RISK 0 · CLEAR line and zone clear RISK 0.44 · MARGINAL line clear, zone cut RISK 1 · SHADOWED 49 m below the line · 19.2 dB ground station ridge, the one thing that does not move drone, descending at constant range first Fresnel zone, at the link’s own frequency line of sight through the ground: terrain sets the link’s score risk is 0 while 60 % of the zone is clear and 1 once the ground reaches the line, the same shape as range risk
RISK 0 · CLEARline of sight and first Fresnel zone both clear the ridge
RISK 0.44 · MARGINALthe line clears the ridge, the zone does not
RISK 1 · SHADOWEDthe ground cuts the line: terrain sets the link’s score while it still carries

01Line-of-sight clearance

The elevation profile between two positions, 256 samples, against a sightline bent by the earth’s bulge (k-factor 4/3): does the path clear the ground, and by how many metres.

02Fresnel-zone obstruction

A sightline grazing the ridge still starves the link when the first Fresnel zone is cut. One sampling is evaluated at each local link’s own frequency, so a 915 MHz radio and a 5 GHz radio to the same drone get different answers from the same ground.

03Knife-edge diffraction

The loss at the dominant obstruction, single knife-edge after ITU-R P.526, collapsed with the other two into one terrain risk per path and link: 0 while 60 % of the zone is clear, 1 once the ground reaches the line.

INPUTS PER PATH PER LINK FREQUENCY ONE NUMBER TWO CONSUMERS Elevation tilesloaded on the node Positionsthis node’s fix · adverts Path profile256 samples · earth bulge Line of sightclearance in metres First Fresnel zoneat each link’s frequency Knife-edgediffraction loss in dB Terrain risk0 to 1, or unknown Link scoresat once · this node’s fix Route costsnext advert · advertised positions Unknown is not clear: a position off the tiles, or a path that leaves them, carries no risk and no penalty. Advisory: terrain raises a cost. Only missed probes declare a link dead, so a shadowed link that still answers stays as a last resort.
PER PATHline of sight with the earth’s bulge, the first Fresnel zone at each link’s frequency, knife-edge diffraction
AT ONCEthis node’s link scores, from its own latest fix
ON THE NEXT ADVERTroute costs on every node, from advertised positions, so every node agrees
Steering

Link scores at once, routes on the next advert

Terrain risk joins the signal and range risks with one maximum, in two places. The scheduler, choosing between this node’s own links, uses its latest fix and reacts within one pass: a shadowed link’s loss is inflated by up to three quarters, the ceiling signal and range use, and traffic walks onto the link that still sees. The shortest-path routing weighs every edge from advertised positions at the default frequency, up to four times its cost, so every node holding the same tiles computes the same weights from the same adverts, and the routes stay loop-free. Each path is assessed now and over the prediction look-ahead along both nodes’ velocities, and the worse of the two counts.

Advisory

Never declares a link dead

Terrain raises a cost. It never marks a link down and never changes a measured value: a fully shadowed link whose probes still answer stays alive as a last resort, and only missed probes declare death. [terrain] prediction = false keeps the analysis, the snapshot and the 3D view and steers nothing, and it applies live.

Unknown

Unknown is not clear

A position outside the tiles, or a path that leaves them, is unknown: no risk value and no penalty, drawn grey and never green. A node without a fix is reported as having none. A fix reported below the ground is lifted onto it before the antenna height is added, so a ground station whose GPS altitude sits on the ellipsoid does not read every path as blocked.

Tiles

Elevation on the node, nothing fetched

The node reads tiles baked from free elevation data, SRTM, NASADEM or Copernicus GLO-30, from its own disk. Where tiles overlap, the finest answers, so a detailed crop of the valley overrides a coarse regional tile. A memory cap bounds them, and a tile that will not load costs only its own coverage: terrain is advisory and never stops the tunnel. The dashboard’s 3D grid comes from the same tiles, served by the node, with no tile server, so it works air-gapped. The step-by-step guide is on the developer portal, for approved engineering accounts. load a tile ↗

Cost

Bounded CPU

A pass runs every second, or within 250 ms of a position moving, and assesses at most 512 paths, this node’s neighbours first. One 256-sample path costs about 6 µs on a desktop processor, so a full 512-path pass takes about 3 ms of CPU.

Reporting

What the node says about it

The stats snapshot carries a terrain block: the tiles, this node’s own state, and per neighbour its state, risk, clearance, Fresnel obstruction, diffraction loss and distance, with the risk and a steering flag per local link. Entering and leaving shadow is journalled as link.terrain_shadow and link.terrain_clear, and counters say how many routes and link scores terrain moved. GET /api/terrain lists the tiles the node holds.

The ground in 3D, on the node’s own dashboard

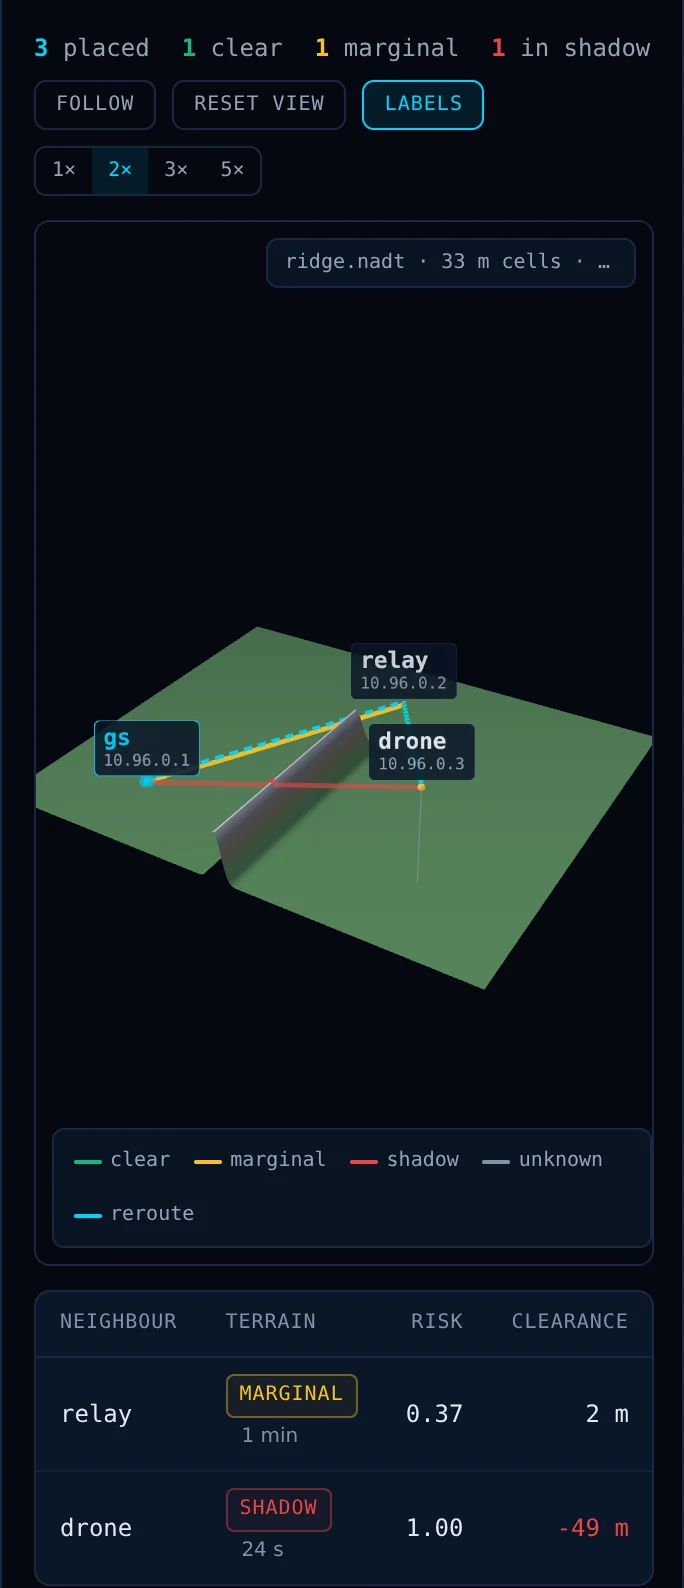
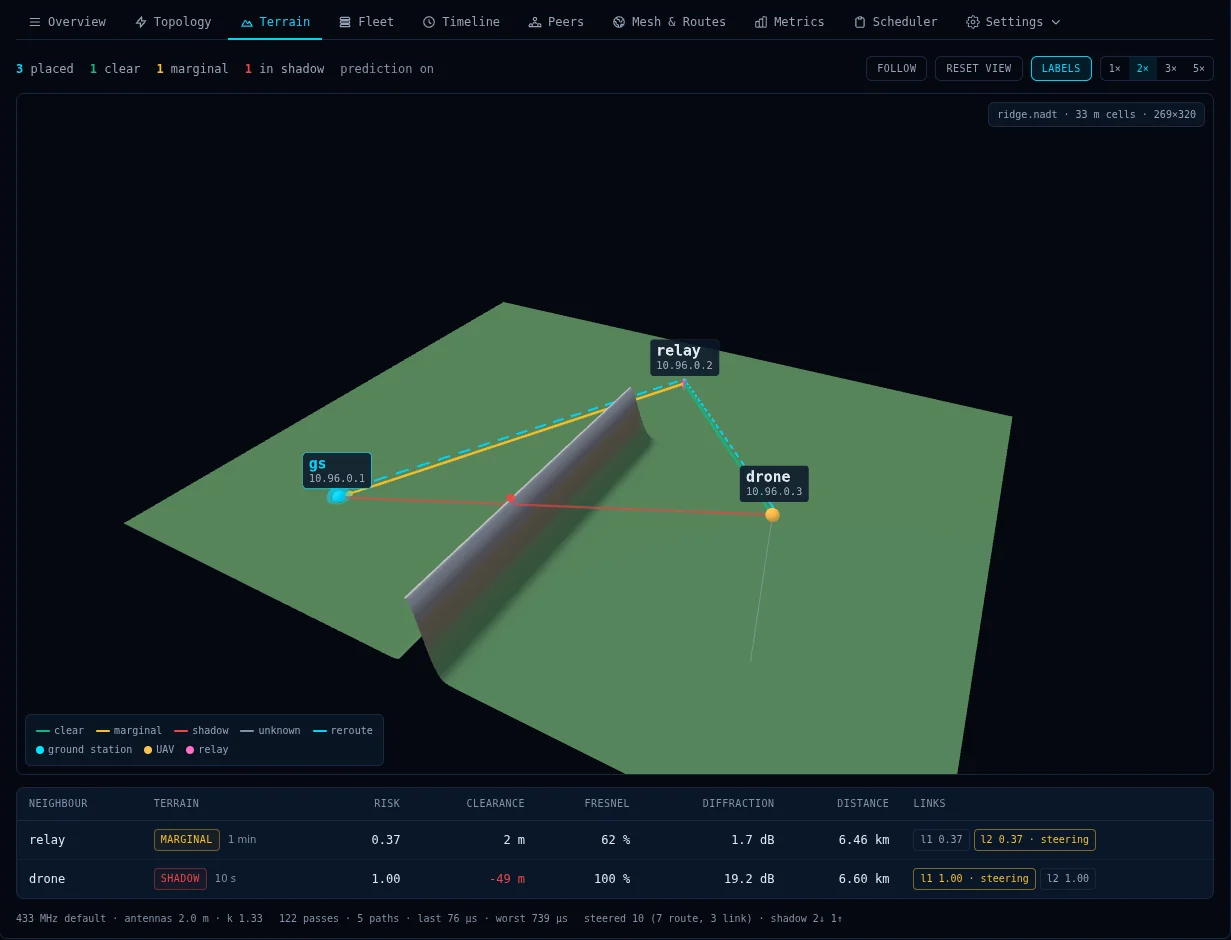
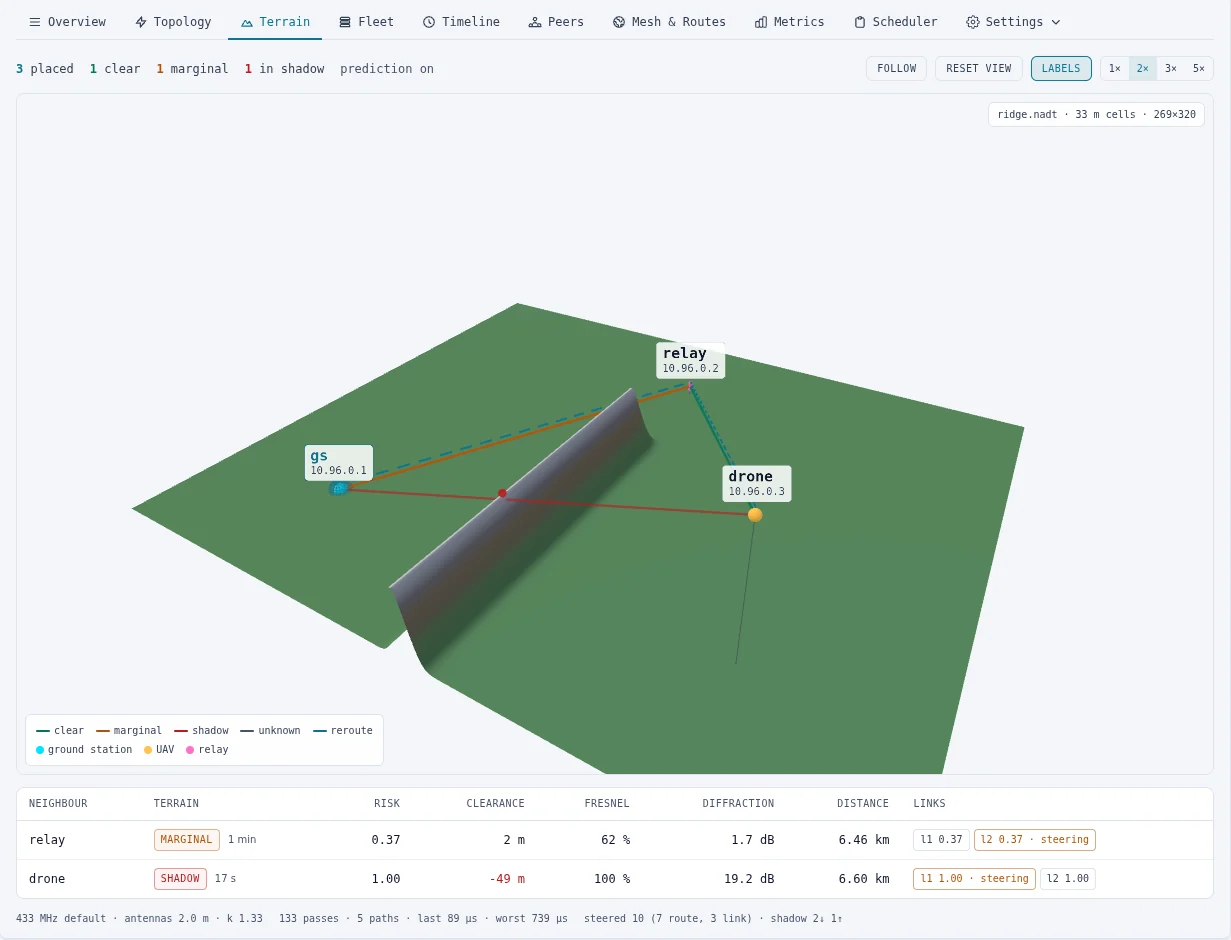
A Terrain tab beside Topology draws the node’s grid as a lit, elevation-coloured surface, every positioned node at its real latitude, longitude and altitude with its platform symbol, a pole to the ground and a velocity arrow, and every link coloured by line of sight: clear green, marginal amber, shadow red, unknown grey. A shadowed path shows its worst obstruction and the reroute through the relay the node’s routes actually use. Orbit, zoom and pan; follow this node; exaggerate the relief up to five times; click a node or a link for its readout. A per-neighbour table sits below, and the 3D code loads only when the tab opens.

Dashboard Terrain tab: a ridge across an elevation surface, a ground station, a hilltop relay and a drone at their positions; the direct ground-station-to-drone path in red with its worst obstruction marked on the ridge, the path to the relay in amber, and a cyan dashed reroute through the relay; below, a table with the relay marginal at risk 0.37 and the drone in shadow at risk 1.00, 49 metres below the line of sight with 19.2 dB of diffraction
The Terrain tab with the drone behind the ridge: the direct path red with its worst point on the crest, the reroute through the relay dashed in cyan, and the per-neighbour table with each link’s risk and which one terrain is steering.
The same Terrain tab in the light theme
Light theme.
The Terrain tab at phone width: the controls wrap above the 3D view and the table below it
Phone width.
Ridge Valley — two ground stations either side of a fixed massif, three relays flying patrolsSimulation
—current route
—weakest hop clearance
0route changes
0 mstime routed over a dead hop
What you’re watching: a browser simulation of the geometry on synthetic terrain. Turn terrain awareness off and the chain re-forms only after a hop dies; with it on, the route moves while the hop still carries. The node does the same against the elevation tiles loaded on it, and the mission simulator draws a fleet over real elevation data.
Boundaries

Same tiles everywhere, one advert behind

Every node holds the same tiles: nodes with different tiles weigh the same edge differently, which link-state cannot keep loop-free, and the hop limit bounds any loop. A moving node’s position reaches the others within about a second of moving 25 m and at least every 10 s while it moves, so routing follows it one position advert behind, while that node’s own link scores react within a pass; velocity projection reaches only the prediction look-ahead. Diffraction is a single knife-edge, so several ridges in a row are not summed, and there is no clutter or building model beyond what a surface model such as GLO-30 carries. One antenna height applies to every node, tiles and positions are taken to share a vertical datum, and the 3D view draws the elevation without a map drape.

Relay selection

The same projection picks the next hop.

Prediction doesn’t only choose between the links on one hop — it chooses which neighbour to route through. Relay B is the lower-cost hop and is opening range; relay C is marginal and closing. Route metrics are sticky by design, so a reactive mesh holds B until the path actually fails and pays for everything in flight; the projected margin gives the SPF cost a reason to move ten seconds early instead.

Relay handover in a moving mesh — one scripted pass, run in both modesSimulation
Prediction
RELAY Bcarrying relay
—handover lead time
0packets lost this run
What you’re watching: one scripted 34-second pass, identical in both modes, so the two runs compare — the footer timeline always carries both outcomes, one lit and one ghosted. Prediction only ever raises B’s routing cost as its projected margin approaches the floor; probes stay the sole authority on death, and B keeps carrying them after the traffic has left. Turn prediction off and the route holds B until the measurement fails, then waits out five missed probes with the stream still pointed at a dead neighbour.

Why a mesh doesn’t simply follow the strongest signal

It could — and it would flap. Route dampening exists because re-converging on every telemetry wobble costs more than it saves, so a link-state mesh keeps its next hop while that hop is usable and re-runs SPF when something breaks. Prediction resolves the tension without loosening the damping: the projected margin is just another term in the same per-link cost, so the route moves once, deliberately, at a moment of the operator’s choosing rather than at the moment of failure.

The fold

One risk model.

Range risk, signal risk and terrain risk fold into a single per-link score with a .max(): whichever threat arrives first drives both the per-packet scheduler and the multi-hop route costs.

signal riskrange riskterrain riskinterference-zone risk — research

One mental model, one tuning surface, one number to read in the stats snapshot. And the fold is open by design — the next layer under research puts declared interference zones — EW and EMCON — on the same map as terrain.

The shape of the thing

From reactive routing to predictive control.

Strip away the features and one substitution is left: the scheduler’s inputs stop being measurements of the recent past and start being projections of the near future. Signal trend, closing velocity, range envelope and terrain shadow collapse into one per-link risk score that runs seconds ahead of the radio, and both the per-packet scheduler and the SPF costs consume it.

That is the reframing: not “find a path that works”, but a control loop holding a model of its own next few seconds. And the discipline that keeps it honest hasn’t moved — prediction biases costs, probes decide truth, and every projection is inspectable in the stats snapshot.

Request an evaluation

Hand over before it drops.

If your platforms move, reactive failover is already too late. Bring a mission profile and we’ll walk the prediction pipeline against it.